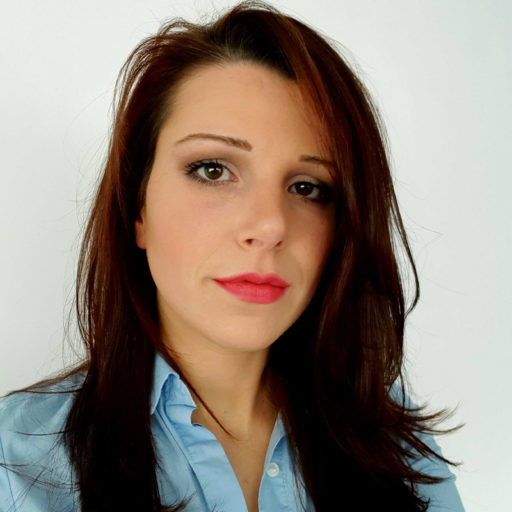
About me

Who I Am

I am an Industrial Engineer with a degree in Electrical Engineering and a specialization in Industrial Automation.
My academic journey concluded with a PhD in Robotics, where I focused on system design, control, and emerging technologies for innovation.

After a period of research, in 2018 I founded my own engineering firm, with the goal of providing companies and professionals with technical expertise and digital innovation.

What I Do

Today, I combine my background as a technical engineer with my skills as a software developer, offering services that range from technical consulting and industrial reports to the development of advanced digital solutions.

Specifically, I work on:

  • Software development: servers, web apps, mobile apps, and integrated applications with Artificial Intelligence, Machine Learning, and IoT.
  • Technical consulting and reports: support for companies applying for state incentives, Energy Performance Certificates (EPC/APE), CE compliance for software and machinery, and industrial assessments.
  • SEO and digital business consulting: strategies to improve online visibility and integrate digital processes into business workflows.
  • Professional training: courses for managers, developers, and technical professionals on AI, Prompt Engineering, RPA, and digital innovation.
  • Project management and innovation governance: leading complex digital transformation projects, from infrastructure assessment to phased planning, through to governance of architectural choices and AI adoption, for SMEs and Public Administration.

My Approach

Each project is based on a practical, results-oriented approach: not just theory or documentation, but real solutions that can be applied immediately.

Whether it’s developing custom software, writing an industrial report, or guiding a team through training, my goal is always the same: to help companies and professionals grow, embrace digital transformation, and face future challenges with confidence.

How I Can Help


If you are looking for an Industrial Engineer with cross-disciplinary expertise in technical consulting, industrial automation, and software development, I can provide complete support that combines engineering precision with digital creativity.

If you want to mail me, don’t hesitate, or WhatsApp!

Below you’ll find my full profile, always up to date. Explore the experiences or download the full CV or a customized version based on the applied filters.

Elisabetta Cataldi

Engineer

Engineer and software consultant specialized in development, SEO, and technical compliance.
I support companies and professionals in building scalable digital solutions and managing technical assessments and CE compliance for software and systems.

Where technology meets compliance and real-world execution.

I help companies and professionals design and build software solutions while managing technical and regulatory requirements in a clear and practical way.

  • Via Piternis 6 c Cervaro, 03044 Frosinone, Italy
  • info@elisabettacataldi.it
  • +39 3331327607
  • Place of birth: Cassino
  • Date of birth: 02/09/1988
  • Project management and innovation governance (assessment, roadmap, delivery)

Reset

My journey combines engineering, software development, and technical compliance.

Over time, I have worked on projects that required not only strong technical skills but also the ability to interpret regulations, produce documentation, and ensure system compliance.

Today, I bring these elements together to provide end-to-end support: from design and development to validation and technical assessment.

Freelance Engineer – Technical Consulting, Software Development and Training

Studio di Ingegneria Elisabetta Cataldi

2018
  • Consulting
  • Hybrid
  • Professional experience

Since 2018, consulting and training as a freelance engineer, combining an academic background in automation and robotics with hands-on experience in software development.

Assignments are run as complete projects, with direct responsibility for the client relationship, goals and scope, planning, architectural choices and delivery: requirements and business process analysis, architecture design, development and integration of solutions, technical documentation, client support and knowledge transfer to in-house teams.

The main areas are the digitalisation of production and document processes, automation with RPA, n8n and AI agents, compliance of software and machinery with European requirements, technical appraisals for tax incentives, and the design and delivery of technical training for companies and professionals.

Learn more

Digital Innovation and Document Transformation Consultant

Studio di Ingegneria Elisabetta Cataldi

2026
  • Software project
  • Hybrid
  • Professional experience

Consulting assignment to guide an engineering and maintenance SME, with clients in public administration and defence, towards digital and structured management of documents and processes.

The work started with an assessment of the existing infrastructure (virtualisation, Active Directory, NAS, network, security and backup) and the mapping of roles, access rights and document flows. On this basis a hybrid Microsoft 365 / SharePoint Online architecture was designed, keeping sensitive data on-premise, together with the integration with the company's vertical management system and a local OCR/AI solution for document classification, in line with the data sovereignty required by defence clients.

Instructor – Architecture and Integration of Modern Robotic Systems (ROS2, PLC, AI and Simulation)

Professional training consultancy

2026
  • Training delivered
  • Remote
  • Teaching and training

A 24-hour training programme in seven modules that takes participants from the overall architecture of a modern robotic cell (robot, ROS2, PLC, vision, SCADA and AI) to the hands-on integration of each component.

The course compares PLC-centric and ROS-centric architectures and industrial communication protocols (OPC-UA, MQTT, EtherCAT), introduces ROS2 with Gazebo simulation of a robotic arm or mobile robot, and covers ROS2–PLC integration through OPC-UA and MQTT bridges, exchanging commands and signals with a simulated PLC.

The programme continues with machine vision using OpenCV and neural networks for defect classification and anomaly detection, SLAM and LIDAR–IMU sensor fusion for autonomous mobile robots (AMRs), multi-robot coordination and task scheduling, production digital twins and an introduction to CI/CD pipelines with Docker. Every module includes labs in a simulated environment.

Instructor – Enterprise Automation with n8n

Professional training consultancy

2026
  • Training delivered
  • Teaching and training

Professional course for IT teams and process owners who want to adopt n8n as an automation platform in a business context.

The programme follows the real phases of a project: positioning n8n against the alternatives and architectural choices, building robust workflows with data and error handling, extending them with custom Python logic, orchestrating AI/LLM models with confidence scores and decision routing. A module on security and governance and the guided drafting of the pilot project document close the course.

Project and Architecture Lead – Modular AI Agent Platform

Independent project

2026
  • Software project
  • Remote
  • Projects

Applied research and development of an AI agent platform designed to automate complex professional tasks while keeping human control over critical steps. The role covers the product vision and use cases, requirements analysis, the development roadmap and AI governance choices: which decisions to delegate to agents, where to place human review, how to balance cost, quality and data confidentiality.

On the technical side the architecture is modular: an orchestration layer breaks requests down into tasks and assigns them to specialised agents; a memory layer keeps context across sessions and projects; a selection component picks the most suitable model in terms of cost, quality and confidentiality. Workflows are closed-loop, with human-in-the-loop checkpoints before relevant decisions.

Technical Project Manager – Odoo ERP Evolution for a Field Services SME

Studio di Ingegneria Elisabetta Cataldi

2026
  • Software project
  • Remote
  • Professional experience

Technical project management assignment for a field services SME that used Odoo only for accounting and wanted to make it the company's single management system.

The work started with interviews and as-is process mapping, led to the definition of the target architecture (cloud vs on-premise assessment and Odoo Custom Online constraints) and to a phased project plan: sales, warehouse, technician and route management, POS and tax compliance, API integrations for the operators' area. In parallel, an end-to-end subscription flow with electronic signature and recurring payments was designed and proposed to address an urgent security need raised by the client.

Instructor – AI Applied to Cyber Security

Professional training consultancy

2025
  • Training delivered
  • Remote
  • Teaching and training

Training programme for IT and security professionals who want to understand and apply AI techniques to defensive processes.

The course explains the main machine learning approaches for anomaly detection on logs and network traffic, event classification and prioritisation, the use of language models to support incident analysis and threat intelligence, and the automation of repetitive security team tasks. The programme closes with the specific risks of AI systems and the limits to consider when adopting them.

Instructor – ChatGPT for Professional Use

Professional training consultancy

2025
  • Training delivered
  • Remote
  • Teaching and training

Training programme for professionals and technical teams who want to use ChatGPT productively, knowingly and safely.

The course explains how language models work and their limits, prompt engineering techniques (role, context, examples, format constraints), using the model to write and review technical documents, generate and explain code, produce documentation and analyse text. A dedicated part covers output verification, data confidentiality and integration into business workflows.

Instructor – Cross-Platform Mobile Development with React Native

Professional training consultancy

2025
  • Training delivered
  • Remote
  • Teaching and training

Training programme for web and mobile developers who want to build Android and iOS applications from a single codebase.

The course starts from React fundamentals and component structure, covers screen navigation, state management, adaptive user interfaces, access to native device features and integration with REST APIs and backend services, through to debugging, testing and preparing apps for store release.

Instructor – Cybersecurity and Reliability for IoT Systems

Professional training consultancy

2025
  • Training delivered
  • Remote
  • Teaching and training

Advanced training programme for engineers and operations teams running IoT infrastructures and distributed systems.

The course combines Site Reliability Engineering principles (SLIs, SLOs, error budgets) with security practices: incident management, root cause analysis, dashboard and alerting design, and observability through metrics, logs and traces. Threat intelligence, network and device security and references to industry standards complete the programme.

Instructor – From R to SAS

Professional training consultancy

2025
  • Training delivered
  • Remote
  • Teaching and training

Training programme for people who already know R and need to work in environments where SAS is the standard, such as the pharmaceutical, financial and insurance sectors.

The course compares the two languages starting from what participants already know: data structures and datasets, data import and cleaning, transformations, joins and aggregations, statistical analysis and reporting. Each topic comes with side-by-side R/SAS examples and exercises migrating real workflows.

Instructor – Implementing DevSecOps

Professional training consultancy

2025
  • Training delivered
  • Remote
  • Teaching and training

Hands-on advanced course for DevOps and security teams, based on chapters 7–12 of the Linux Foundation LFS262 programme (Implementing DevSecOps) and delivered online over two 8-hour days.

The first day covers security at build and deployment time: vulnerability scanning of images and dependencies with Trivy, Grype and Anchore, image signing with Cosign, container hardening and dynamic application security testing (DAST) with OWASP ZAP integrated into the CI/CD pipeline.

The second day focuses on infrastructure and runtime: validating Terraform and Ansible with Checkov, Terrascan and KICS and policy as code, Kubernetes security (RBAC, Network Policies, Pod Security Standards, Admission Controllers), secrets management with HashiCorp Vault and Sealed Secrets, and runtime anomaly detection with Falco. In the labs, participants build a pipeline with automated image scanning and an environment combining IaC policies, Vault and Falco, ending with a simulated breach and an automated webhook response.

Instructor – Prompt Engineering and Generative AI for Developers

Professional training consultancy

2025
  • Training delivered
  • Remote
  • Teaching and training

Training programme for developers and technical teams who want to bring generative AI into their daily work in a structured and verifiable way.

The course covers the design of reusable technical prompts, code generation and refactoring, automated test generation, algorithmic complexity analysis, effort estimation with function points and documentation generation. A dedicated part addresses integrating models into applications through APIs and building interfaces that use them.

Each module alternates theory and hands-on exercises, with attention to model limitations, output verification and security good practices.

Instructor – SAS Programming (New Edition)

Professional training consultancy

2025
  • Training delivered
  • Remote
  • Teaching and training

Updated edition of the SAS Programming course, redesigned based on feedback from previous editions.

In addition to the core topics (DATA step, procedures, data import and export, transformations and statistical analysis), the new edition gives more room to guided exercises and applied cases on real datasets, with the goal of enabling participants to build complete and reusable analysis workflows on their own.

Product and Development Lead – Word AI Generator, LLM-Based Technical Document Generator

Independent project

2025
  • Software project
  • Hybrid
  • Projects

Ownership of the product throughout its lifecycle: analysis of the needs of people producing technical documentation, definition of features and priorities, decisions on architecture, API key security and usage model, release planning and collection of feedback for later versions. The software was also used as the basis for lab exercises on using LLMs.

On the technical side, the Python application lets users define the document structure through parameters (outline, tone, audience, section length), generates content section by section through the ChatGPT API, exports it to Word and allows templates to be saved and reused.

Project Lead – SEO and AI Dashboard for Tracking, Automation and Funnel Analytics

Independent project

2025
  • Software project
  • Hybrid
  • Projects

Set-up and governance of the project starting from business goals: definition of KPIs and the funnel model, tool selection, design of the data architecture across websites, CRM and reporting, planning of implementation phases and use of the results to steer content and campaign decisions.

On the technical side, the system collects data through GA4 cross-domain tracking and custom events, visualises it in Looker Studio dashboards for organic traffic, conversions and funnels and connects contacts to FluentCRM. n8n workflows automate lead segmentation, email sequences and reporting, with AI models supporting the analysis of content and organic performance.

Instructor – Apache Solr

Professional training consultancy

2024
  • Training delivered
  • Remote
  • Teaching and training

Technical programme for developers and system administrators who design and operate search over large document collections.

The course covers the Solr and SolrCloud architecture, schema design, document indexing, analyser and language filter configuration, query syntax and relevancy tuning, faceting and highlighting. An operational part addresses load testing, monitoring and troubleshooting the most common production issues.

Instructor – Apache Solr Search Engine

Professional training consultancy

2024
  • Training delivered
  • Remote
  • Teaching and training

Course on designing, configuring and operating enterprise search engines based on Apache Solr.

The course starts from the platform architecture and schema design and moves on to indexing text content, configuring analysers and filters, writing queries, tuning result relevancy and highlighting. An operational part covers load testing, troubleshooting and good practices for running Solr in production.

Instructor – RPA for Managers

Professional training consultancy

2024
  • Training delivered
  • Remote
  • Teaching and training

Course for people who need to decide on and govern Robotic Process Automation projects without necessarily being developers.

The course explains how to identify candidate processes, assess their return, design bots and manage their lifecycle. Through applied cases it shows integration with legacy systems, data extraction from applications and websites, interaction with databases and mailboxes, as well as security, credential management and operational monitoring.

Instructor – RPA with Automation Anywhere

Professional training consultancy

2024
  • Training delivered
  • Remote
  • Teaching and training

Hands-on training programme for developers and analysts who build RPA solutions in a business context.

The course takes participants through the full bot lifecycle: process analysis, design, development with Automation Anywhere, integration with Excel workbooks, databases, mailboxes and legacy applications, exception handling, credential security, scheduling, monitoring and production release.

Instructor – SAS Programming

Professional training consultancy

2024
  • Training delivered
  • Remote
  • Teaching and training

Training programme for analysts and data specialists working with SAS in business, healthcare or research settings.

The course covers the structure of SAS programs, reading and writing data from different sources, the DATA step for transformations, filters and derived variables, combining datasets, the main analysis and reporting procedures and organising code into reusable workflows, with exercises on real datasets.

Instructor – Software Architecture and Design (Core and Advanced)

Professional training consultancy

2024
  • Training delivered
  • Remote
  • Teaching and training

Training programme for senior developers and aspiring software architects, structured in a core and an advanced level.

The course covers design principles (SOLID, cohesion and coupling), decomposing a system into components and modules, the main architectural styles and patterns (layered, hexagonal, event-driven, microservices), quality attributes such as maintainability, scalability, security and performance, and the trade-offs between them. A dedicated part addresses documenting architectural choices and communicating them to the team and stakeholders.

Project and Development Lead – PiProxyHub, Hardware/Software Platform for Mobile Proxies

Independent project

2024
  • Software project
  • Hybrid
  • Projects

Ownership of the project from idea to working prototype, responsible for product goals, requirements and scope, hardware and software architecture choices, development planning and the commercial roadmap for international distribution, including market analysis and feature prioritisation.

On the technical side, a low-cost proxy node based on Raspberry Pi and USB SIM modems, with a React web management panel, a Flask or FastAPI API backend and a data processing module for parsing, pattern recognition, file classification and export.

Adaptive Trajectory Tracking for Quadrotor MAVs in Presence of Parameter Uncertainties and External Disturbances

IEEE Transactions on Control Systems Technology, vol. 26, 2018

2018
  • Publication
  • Research and publications

Co-authored paper (G. Antonelli, E. Cataldi, F. Arrichiello, P. Robuffo Giordano, S. Chiaverini, A. Franchi) published in IEEE Transactions on Control Systems Technology, vol. 26, pp. 248-254, 2018.

The controller removes two common simplifying assumptions: it accounts for external forces and moments acting on the vehicle and for a geometric centre that does not coincide with the centre of mass. The control law adapts online to these disturbances and to the uncertain parameters. The paper includes a stability analysis and numerical simulations, and builds on the experimental results presented at IROS 2013.

Research Fellow – Interaction Control for Robotic Systems

Università degli Studi di Cassino e del Lazio Meridionale

2018
  • Research
  • On-site
  • Research and publications

Research activity carried out at the University of Cassino and Southern Lazio after completing the PhD.

The work focused on control strategies that allow robotic systems to interact physically and safely with the environment, in particular aerial and underwater platforms equipped with manipulators. It included modelling, the design of impedance and admittance control laws, numerical simulation, support for experimental validation and the dissemination of results through scientific publications and collaborations within European research projects.

PhD Research – Floating-base arm-equipped systems: kinematic and dynamic control and planning

Università degli Studi di Cassino e del Lazio Meridionale

2016
  • Research
  • On-site
  • Education

Three-year PhD research programme at the University of Cassino and Southern Lazio on floating-base robotic systems carrying manipulators.

The research addressed the unified kinematic and dynamic modelling of vehicle-manipulator systems, adaptive and coordinated control laws robust to parameter uncertainties and external disturbances, and motion planning for aerial and underwater manipulation tasks. The results were validated in simulation and on real platforms, also during research periods abroad at CATEC (Seville) and LAAS-CNRS (Toulouse), and published in international journals and conferences.

Technical High School Diploma in Chemistry – ITIS E. Majorana

Chemistry specialization, with vote 82/100. · Istituto Tecnico Industriale E. Majorana

2007
  • Education

Technical high school diploma with a specialisation in industrial chemistry, final grade 82/100.

Consultant – Software Compliance and CE Marking

Independent professional practice

  • Consulting
  • Technical consulting

Consulting for machine manufacturers, system integrators and software houses that need to demonstrate compliance of their products with European requirements, including those introduced by the Machinery Regulation (EU) 2023/1230 for software-based safety functions and protection against data corruption.

The assignment covers the analysis of applicable requirements, risk assessment, verification of cybersecurity and data integrity measures, drafting and review of technical documentation and supporting the client on the path to CE marking.

Consultant – Software Energy Efficiency and Certification

Independent professional practice

  • Consulting
  • Technical consulting

Strategic and technical support for companies that develop or use software and want to prepare for the evolving European regulatory framework on the energy efficiency and sustainability of digital systems.

The work includes analysis of the regulatory context, definition of metrics and methods for measuring computational consumption, technical audits of existing applications and identification of optimisation measures on code, architecture and infrastructure, with the supporting documentation.

Energy Assessor – Energy Performance Certificates (APE)

Independent professional practice

  • Consulting
  • Technical consulting

Professional activity as a qualified energy assessor for buildings.

Each assignment includes a site survey of the building envelope and systems, collection of documentation, modelling and calculation of energy performance with dedicated software, issuing the certificate and submitting it to the regional energy register. The service also identifies the most effective renovation measures to improve the building's energy class.

Technical Appraiser – Transition 4.0 / 5.0 and Super-Depreciation

Independent professional practice

  • Consulting
  • Technical consulting

Support for companies investing in machinery, plants, software and AI systems that want to access the tax credits and super-depreciation provided by the Italian Transition 4.0 and 5.0 plans.

The work includes a preliminary eligibility check, site inspection, analysis of technical features and of interconnection and integration with company information systems, assessment of software and AI systems against the reference technical annexes, and drafting of the sworn technical appraisal with its supporting documentation.

Measuring Software Performance and Energy Consumption

Independent research and experimentation

2025
  • Research
  • Projects

Applied research on measuring software performance and energy efficiency.

The work covered the definition of computational KPIs (execution time, CPU and memory usage, I/O) and their correlation with energy consumption, the comparison of measurement tools and methods and the design of repeatable test protocols. The results are the technical basis for the consulting work on future software energy certification.

Instructor – Apache Tomcat

Professional training consultancy

2024
  • Training delivered
  • Remote
  • Teaching and training

Technical programme for system administrators and developers running Java web applications in production.

The course covers Tomcat's architecture and main configuration files, application deployment, connector, virtual host and TLS certificate configuration, resource and connection pool management, logging, JVM and performance tuning, and techniques for diagnosing the most common issues.

Instructor – Enterprise Integration with WSO2

Professional training consultancy

2024
  • Training delivered
  • Remote
  • Teaching and training

Technical programme for architects and developers who need to integrate heterogeneous applications and expose services in a governed way.

The course introduces the WSO2 components for integration and message mediation, API publishing and lifecycle management (security, policies, throttling, analytics) and identity and access management with standards such as OAuth2 and OpenID Connect, framing them within a service-oriented enterprise architecture.

Instructor – Process Modelling with BPMN 2.0

Professional training consultancy

2024
  • Training delivered
  • Remote
  • Teaching and training

Training programme for analysts, process owners and IT teams who need to describe business processes in a shared and unambiguous way.

The course presents the BPMN 2.0 notation (events, activities, gateways, flows, pools and lanes, messages) and its use for mapping as-is processes, identifying inefficiencies and bottlenecks and designing to-be processes. Exercises on real cases show how a well-built model becomes the foundation for workflow automation and digitalisation.

Instructor – ServiceNow

Professional training consultancy

2024
  • Training delivered
  • Remote
  • Teaching and training

Technical programme for IT teams and functional analysts adopting ServiceNow for service management.

The course introduces the platform and the ITIL-aligned ITSM processes (incident, problem, change and request management), service catalogue configuration, digital workflow and assignment rule design, SLA, notification and report management, and good practices for adapting the platform to business processes.

Instructor – Test Automation with HP UFT

Professional training consultancy

2024
  • Training delivered
  • Remote
  • Teaching and training

Technical programme for testers and quality assurance teams who want to automate functional testing of enterprise applications.

The course starts with test recording and object repository management, continues with VBScript scripting, checkpoints, parameterisation and data-driven testing, and covers the design of reusable test frameworks, test case management and the execution of regression suites within the QA process.

RPA Project Lead – Industrial Bots with Automation Anywhere

Training and applied project

2024
  • Software project
  • Projects

Use cases run with a project lead approach: analysis of candidate processes and assessment of the return on automation, prioritisation, phase planning, governance and audit rules, release and monitoring criteria. The work also became training material for the RPA courses.

On the technical side, design and development of bots for Excel processing, database interaction and email automation, with error handling, scheduling and unattended execution, security controls and traceability of operations.

Instructor – Ceph Distributed Storage

Professional training consultancy

2023
  • Training delivered
  • Remote
  • Teaching and training

Technical programme for system administrators and infrastructure architects who design or operate large-scale distributed storage.

The course explains Ceph's architecture and components (monitors, OSDs, managers, the CRUSH algorithm), the different data access models (object storage through RADOS Gateway, RBD block devices, the CephFS file system), replication and erasure coding strategies, scalability and fault tolerance, through to integration with virtualisation and cloud-native platforms and day-to-day cluster monitoring.

Instructor – Microsoft SQL Server

Professional training consultancy

2022
  • Training delivered
  • Remote
  • Teaching and training

Training programme for developers and technical staff who use SQL Server as the data layer of business applications.

The course covers relational modelling and normalisation, T-SQL querying (joins, aggregations, subqueries, window functions), programming with views, stored procedures and triggers, index management and performance basics, through to essential administration tasks such as security, backup and restore.

Technical Project Lead – Blockchain for University Degree Certification

Earlier project

2022
  • Software project
  • Projects

Leadership of the project from requirements gathering to delivery: definition of the degree issuing and verification process, evaluation of technology options and choice of a permissioned blockchain, development planning and coordination across registration logic, application services and user interface.

On the technical side, the system immutably records the fingerprint of documents (degrees, certificates, transcripts) and lets third parties verify them, with registration and verification logic in Python, services and APIs in Node.js and an interface for uploading documents and checking their authenticity.

Technical Lead – Django Backend for an Industrial Scheduler

Earlier project

2021
  • Software project
  • Projects

Project ownership from operational requirements analysis to delivery: definition of the information to manage, design of the integration with the existing industrial scheduler, planning of development and testing.

On the technical side, the Django (Python) backend exposes APIs and administration interfaces to configure activities, manages their scheduling and execution status and keeps a history of operations for monitoring and analysis.

Technical Lead – Messenger, Real-Time Chat Platform

Earlier project

2021
  • Software project
  • Projects

Definition of the overall system architecture, the technology choices for real-time communication and the development plan for server and app, with attention to scalability and reliability.

On the technical side, the system consists of a Node.js server based on real-time two-way communication and a React Native mobile app, and handles one-to-one and group conversations, user presence, notifications and message history.

Technical Lead – Video Chat, Real-Time Multi-User Video Conferencing

Earlier project

2021
  • Software project
  • Projects

Definition of the system architecture and the technology choices for real-time audio and video communication, planning of backend development and its integration with web and mobile clients.

On the technical side, the Node.js server manages room creation, signalling to establish connections between participants and synchronisation of call states.

Technical Lead – Node.js Backend for Mobile Applications

Earlier project

2020
  • Software project
  • Projects

Definition of the backend architecture as a shared component across several mobile projects: data model, REST API conventions and standards, security and authentication, choices for reusability and long-term maintenance.

On the technical side, the Node.js server exposes REST APIs to client apps, handles user authentication and operations on application data and uses a MySQL database for persistence.

Technical Project Lead – AR Furniture, Augmented Reality App for Interior Design

Earlier project

2020
  • Software project
  • Projects

Project management starting from business needs: definition of the features that support sales, choice of technology for a cross-platform solution, development planning and organisation of the furniture model catalogue.

On the technical side, the app detects room surfaces through the camera and lets users place, move and rotate life-size 3D furniture models, so they can assess size and style directly in their own home.

Technical Project Lead – AR Napoli, Augmented Reality App for Points of Interest

Earlier project

2020
  • Software project
  • Projects

Project management: definition with the client of goals, content and user experience, choice of the technology stack for a cross-platform solution, development planning and coordination of point-of-interest content management.

On the technical side, the React Native app uses GPS, compass and camera to show real-time information cards about nearby points of interest, with text and multimedia content managed by a dedicated backend.

Technical Lead – OCR for Automatic Data Extraction from Documents

Earlier project

2019
  • Software project
  • Projects

Project set-up starting from the process to automate: analysis of the documents and data to extract, definition of accuracy criteria and validation checks, planning of development and integration with business systems.

On the technical side, the system pre-processes images (deskewing, binarisation, noise removal), recognises text with Tesseract, locates the relevant fields through rules and patterns and checks their consistency, producing structured data.

Coordinated control of aerial robotic manipulators: theory and experiments

IEEE Transactions on Control Systems Technology, vol. 26(4), 2018

2018
  • Publication
  • Research and publications

Co-authored paper (G. Muscio, F. Pierri, M. A. Trujillo, E. Cataldi, G. Antonelli, F. Caccavale, A. Viguria, S. Chiaverini, A. Ollero) published in IEEE Transactions on Control Systems Technology, vol. 26, no. 4, pp. 1406-1413, 2018.

The work proposes a coordinated control approach for aerial vehicles equipped with robotic arms, in which the motions of the flying base and of the manipulator are planned and controlled together to perform manipulation tasks. The theoretical framework is supported by experiments on real aerial manipulation platforms.

6D Physical Interaction with a Fully Actuated Aerial Robot

IEEE International Conference on Robotics and Automation (ICRA 2017), Singapore

2017
  • Publication
  • Research and publications

Co-authored paper (M. Ryll, G. Muscio, F. Pierri, E. Cataldi, G. Antonelli, F. Caccavale, A. Franchi) presented at the IEEE International Conference on Robotics and Automation (ICRA) 2017 in Singapore, pp. 5190-5195.

The paper presents Tilt-Hex, a hexarotor with tilted propellers that can control position and orientation independently. Physical interaction is handled by an admittance controller: an outer loop sets the desired admittance behaviour and an inner geometric control loop tracks the pose, while interaction forces are estimated with a momentum-based observer. The work was later extended in the International Journal of Robotics Research (2019).

Examination Board – Automation and Control

University of Cassino and Southern Lazio

2017
  • Teaching
  • On-site
  • Teaching and training

Academic support and student assessment for the Automation and Control course, part of the master's degree in Computer Engineering at the University of Cassino and Southern Lazio. The role included taking part in exam sessions, marking written and oral exams and holding office hours for students.

Advanced ROV Autonomy for Efficient Remote Control in the DexROV Project

Marine Technology Society Journal, vol. 50(4), 2016

2016
  • Publication
  • Research and publications

Co-authored paper (P. Di Lillo, E. Simetti, D. De Palma, E. Cataldi, G. Indiveri, G. Antonelli, G. Casalino) published in the Marine Technology Society Journal, vol. 50, no. 4, pp. 67-80, 2016.

The paper describes how DexROV shifts semi-autonomous underwater operations to onshore control centres: operators work on a simulated seabed built from the robot's own sensing and transmitted by satellite, while the ROV, equipped with two six-degree-of-freedom dexterous arms, runs a multi-task priority control scheme that handles low-level tasks automatically so that the operator can focus on the main job.

Experiments on coordinated motion of aerial manipulators

ICRA 2016

2016
  • Publication
  • Research and publications

Co-authored paper presented at the IEEE International Conference on Robotics and Automation (ICRA) 2016.

The paper reports the experimental validation of coordinated motion control for aerial manipulators, in which the flying base and the arm move together to accomplish the task.

Impedance Control of an aerial-manipulator: Preliminary results

IROS 2016

2016
  • Publication
  • Research and publications

Co-authored paper presented at the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2016.

The paper describes the impedance control strategy developed for an aerial vehicle carrying a robotic arm and the first experimental results of physical interaction with the environment.

Teaching Assistant – Systems Theory (2016/2017)

University of Cassino and Southern Lazio

2016
  • Teaching
  • On-site
  • Teaching and training

University teaching support for the Systems Theory course, master's degree in Computer Engineering at the University of Cassino and Southern Lazio.

The sessions covered modelling and analysis of linear dynamic systems, state-space representations, stability, reachability and observability, with guided exercises in preparation for the exam.

Underwater Intervention Robotics: An Outline of the Italian National Project MARIS

Marine Technology Society Journal, vol. 50(4), 2016

2016
  • Publication
  • Research and publications

Co-authored paper by the MARIS consortium (led by G. Casalino, with M. Caccia, S. Caselli, C. Melchiorri, G. Antonelli, A. Caiti, G. Indiveri and others) published in the Marine Technology Society Journal, vol. 50, no. 4, pp. 98-107, 2016.

The paper outlines the goals and approach of the project: developing the technologies and methods needed for autonomous underwater robots to carry out intervention work, and demonstrating their capabilities at proof-of-concept level on prototype hardware.

Visiting Researcher – Motion planning and admittance control for aerial manipulation (LAAS-CNRS)

LAAS-CNRS

2016
  • Research
  • On-site
  • Research and publications

Research stay in Antonio Franchi's group at LAAS-CNRS, Toulouse, within the European H2020 AEROARMS project on aerial robots with arms for inspection and maintenance.

The work focused on two topics: the development of a planner able to generate feasible motions for aerial-manipulation vehicles while reacting to the environment, and the implementation of admittance control on a fully actuated aerial platform to perform physical interaction tasks. The activity included both algorithm design and experimental testing in the laboratory.

Basic interaction operations for an underwater vehicle-manipulator system

ICAR 2015

2015
  • Publication
  • Research and publications

Co-authored paper presented at the International Conference on Advanced Robotics (ICAR) 2015.

The work addresses the control of an underwater vehicle-manipulator system during elementary interaction tasks with the environment, a key step towards autonomous underwater intervention.

Teaching Assistant – Systems Theory (2015/2016)

University of Cassino and Southern Lazio

2015
  • Teaching
  • On-site
  • Teaching and training

University teaching support for the Systems Theory course, master's degree in Computer Engineering at the University of Cassino and Southern Lazio.

The sessions covered modelling and analysis of linear dynamic systems, state-space representations, stability, reachability and observability, with guided exercises in preparation for the exam.

Virtual decomposition control for an underwater vehicle carrying a manipulator

MRS/IEEE OCEANS 2015

2015
  • Publication
  • Research and publications

Co-authored paper presented at MTS/IEEE OCEANS 2015.

The paper applies the virtual decomposition approach, which splits a complex robotic system into subsystems controlled separately while guaranteeing overall stability, to an underwater vehicle equipped with a manipulator.

Visiting Researcher – Impedance control for arm-equipped quadrotors (CATEC)

CATEC - Centro Avanzado de Tecnologias Aeroespaciales

2015
  • Research
  • On-site
  • Research and publications

Research stay at CATEC (Centro Avanzado de Tecnologías Aeroespaciales), Seville, within the European FP7 ARCAS project on cooperative aerial robots for assembly and structure construction.

The activity aimed at experimentally validating impedance control approaches for a quadrotor carrying a 6-degree-of-freedom manipulator, so that the system could come into contact with the environment in a controlled and safe way. It included preparation of the experiments, implementation of the controller on the real platform and analysis of the results.

Adaptive Control of Arm-equipped Quadrotors. Theory and Simulations

22nd IEEE Mediterranean Conference on Control and Automation (MED 2014)

2014
  • Publication
  • Research and publications

Co-authored paper presented at the 22nd IEEE Mediterranean Conference on Control and Automation.

The paper extends adaptive control to arm-equipped quadrotors, compensating online for uncertainties in the dynamic parameters of both the vehicle and the manipulator, and validates the approach in simulation.

Instructor – Bridging Course for First-Year Students

University of Cassino and Southern Lazio

2014
  • Teaching
  • On-site
  • Teaching and training

Introductory teaching for first-year engineering students at the University of Cassino and Southern Lazio.

The course aimed to align the background knowledge required by first-year courses and to help new students adapt to university study methods, through lectures and guided exercises.

Recursive adaptive control for an underwater vehicle carrying a manipulator

22nd IEEE Mediterranean Conference on Control and Automation (MED 2014)

2014
  • Publication
  • Research and publications

Co-authored paper presented at the 22nd IEEE Mediterranean Conference on Control and Automation.

The paper proposes an adaptive control law formulated recursively along the kinematic chain of an underwater vehicle-manipulator system, which keeps the computational load manageable while compensating for uncertain dynamic parameters.

Experimental validation of a new adaptive control scheme for quadrotors MAVs

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2013)

2013
  • Publication
  • Research and publications

Co-authored paper presented at the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2013.

The paper reports the experimental validation, carried out at the Max Planck Institute for Biological Cybernetics, of an adaptive control scheme for quadrotors that compensates for parameter uncertainties during trajectory tracking.

Instructor – Introductory MATLAB and Simulink Course

University of Cassino and Southern Lazio

2013
  • Teaching
  • On-site
  • Teaching and training

Introductory course for engineering students at the University of Cassino and Southern Lazio, aimed at building the basic skills needed for numerical computing, programming and simulation.

The course combined theory and hands-on exercises: from the MATLAB environment, matrix manipulation, scripts, functions and data visualisation, to building block-diagram models of dynamic systems in Simulink and simulating them.

Master’s Degree in Electrical Engineering

University of Cassino and Southern Lazio

2013
  • Certification
  • On-site
  • Education

Master's degree in Electrical Engineering at the University of Cassino and Southern Lazio, specialising in industrial automation.

The programme covered automatic control, robotics, electrical drives and power systems. The thesis, "Adaptive control for quadrotors", was partly carried out at the Max Planck Institute for Biological Cybernetics in Tübingen, with experimental validation of the proposed control law. Final grade 102/110.

Research Fellow – Adaptive control for vehicle-manipulator systems

Università degli Studi di Cassino e del Lazio Meridionale

2013
  • Research
  • On-site
  • Research and publications

Research activity at the University of Cassino and Southern Lazio, following the master's thesis, on adaptive control techniques for systems made of a vehicle and a manipulator.

The work extended adaptive control laws to rigid-body serial chains on a floating base, so that the controller can compensate online for uncertainties in the dynamic parameters of both the vehicle and the arm. The approach was developed in a recursive and modular form and validated in simulation for aerial and underwater applications.

Visiting Researcher – Adaptive control for quadrotors (Max Planck Institute)

Max Planck Institute for Biological Cybernetics

2012
  • Research
  • On-site
  • Research and publications

Research stay at the Max Planck Institute for Biological Cybernetics in Tübingen as part of the master's thesis work.

The activity consisted of implementing and experimentally validating an adaptive control law for quadrotor micro aerial vehicles, able to track a desired trajectory while compensating for uncertainties in mass, inertia and external disturbances. The results contributed to publications at IROS 2013 and in IEEE Transactions on Control Systems Technology.

Engineer – Design of renewable energy power plants

P.N.O.

2011
  • Employment
  • On-site
  • Professional experience

Technical activity at P.N.O. in the energy sector, dedicated to the design of plants for producing electricity from renewable sources.

The work included preliminary sizing of the plants, definition of the electrical layout, estimation of energy producibility and preparation of the technical documentation supporting the project.

Engineer – Type approval of protection equipment for power lines (smart grid)

CPT Engineering

2011
  • Employment
  • On-site
  • Professional experience

Professional experience at CPT Engineering in the field of electrical power distribution.

The work concerned the approval of protection devices for power lines in a smart grid context: analysis of the applicable technical specifications, preparation and execution of functional tests, verification of the results against requirements and drafting of the technical documentation for approval.

Bachelor’s Degree in Electrical Engineering

University of Cassino and Southern Lazio

2010
  • Certification
  • On-site
  • Education

Bachelor's degree in Electrical Engineering at the University of Cassino and Southern Lazio.

The programme provided the foundations of electrical engineering, electrical machines, electronics, measurements and automatic control. The thesis concerned the design and construction of a test bench to detect eccentricity in single-phase electric motors. Final grade 100/110.

© Copyright 2023 - All Rights Reserved
Privacy Policy and Cookie Policy
Terms and Conditions
Engineer and technical consultant. I help businesses and professionals integrate AI, automation and digital technology into real operational processes.

Elisabetta Cataldi
Privacy Overview

This website uses cookies so that we can provide you with the best user experience possible. Cookie information is stored in your browser and performs functions such as recognising you when you return to our website and helping our team to understand which sections of the website you find most interesting and useful.